A viewpoint planning algorithm based on 7 degree of freedom optical 3D measurement system for the turbine blade measurement
点击次数:
发布时间:2026-09-02
发布时间:2026-09-02
影响因子:6.3
DOI码:10.1109/TMECH.2025.3580952
论文名称:A viewpoint planning algorithm based on 7 degree of freedom optical 3D measurement system for the turbine blade measurement
发表刊物:IEEE/ASME Transactions on Mechatronics
刊物所在地:USA
项目来源:重点研发计划
关键字:Blade measurement, feature extraction, path planning, structured light three-dimensional (3D) mea surement, viewpoint planning
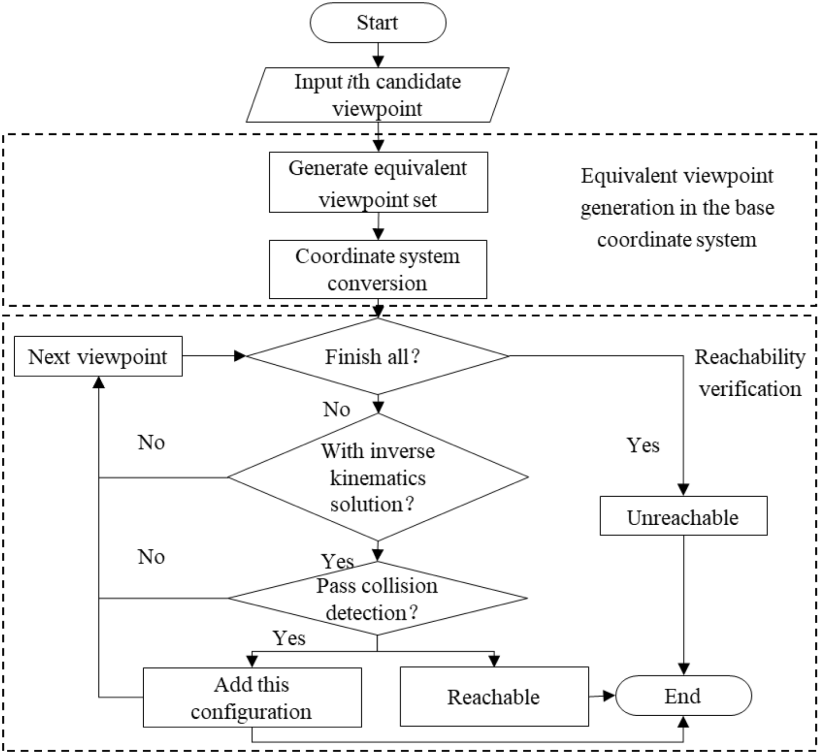
摘要:Optical three-dimensional (3D) measurement is an essential method for improving the efficiency of surface detection for blades in steam turbines, gas turbines, and aircraft engines. The combination of a scanner, a robot, and a turntable provides a flexible and accurate optical 3D measurement scheme. This article proposes a viewpoint planning method for a 7-degrees-of-freedom (DOF) optical 3D measurement system based on measurement feature extraction, which addresses problems such as a large number of ineffective and unreachable viewpoints, a low coverage rate, and viewpoint sequences with long motion time. It reduces the number of invalid viewpoints by extracting measurement features from blades. In addition, viewpoints within a 6 DOF space are sampled by rotating the optical axis of the scanner to improve the coverage rate. Then, the reachability of viewpoints is verified by using equivalent viewpoints for the measurement system with redundant DOF, and many invalid viewpoints are removed to reduce the time cost of the viewpoint visibility evaluation. A generalized traveling salesman problem is constructed by rotating the turntable uniformly, and a collision-free path planning algorithm based on backup solvers is designed. Finally, a third-stage rotating blade of a heavy-duty gas turbine is used as the measurement object for the experiment. The experimental results show that the proposed method improves the measurement coverage by an average of 14.75%, removes an average of 27.97% of unreachable viewpoints, and reduces the time required for viewpoint visibility evaluation time by an average of 153.84 seconds compared to traditional viewpoint sampling methods. Compared to traditional solutions to the traveling salesman problem solutions, it reduces scanning time by an average of 27.44% .
合写作者:江长鸿,王昭,段琼琼,高建民,Quangong He,Song Ai
第一作者:黄军辉
论文类型:期刊论文
通讯作者:于复坤
学科门类:工学
一级学科:机械工程
文献类型:J
卷号:30
期号:6
页面范围:7467-7477
ISSN号:1083-4435
是否译文:否
发表时间:2026-07-10
收录刊物:SCI